Robotics · Research & Engineering

Zeyuan Gao

  • Robotics Researcher
  • Robot Learning
  • 3D Perception
  • Embodied AI

I build perception and robot-learning systems across the full path from data collection and geometric reasoning to real-robot deployment.

Currently working on dual-arm manipulation and deployment-oriented evaluation, following the MRes Medical Robotics and Image-Guided Intervention programme at Imperial College London.
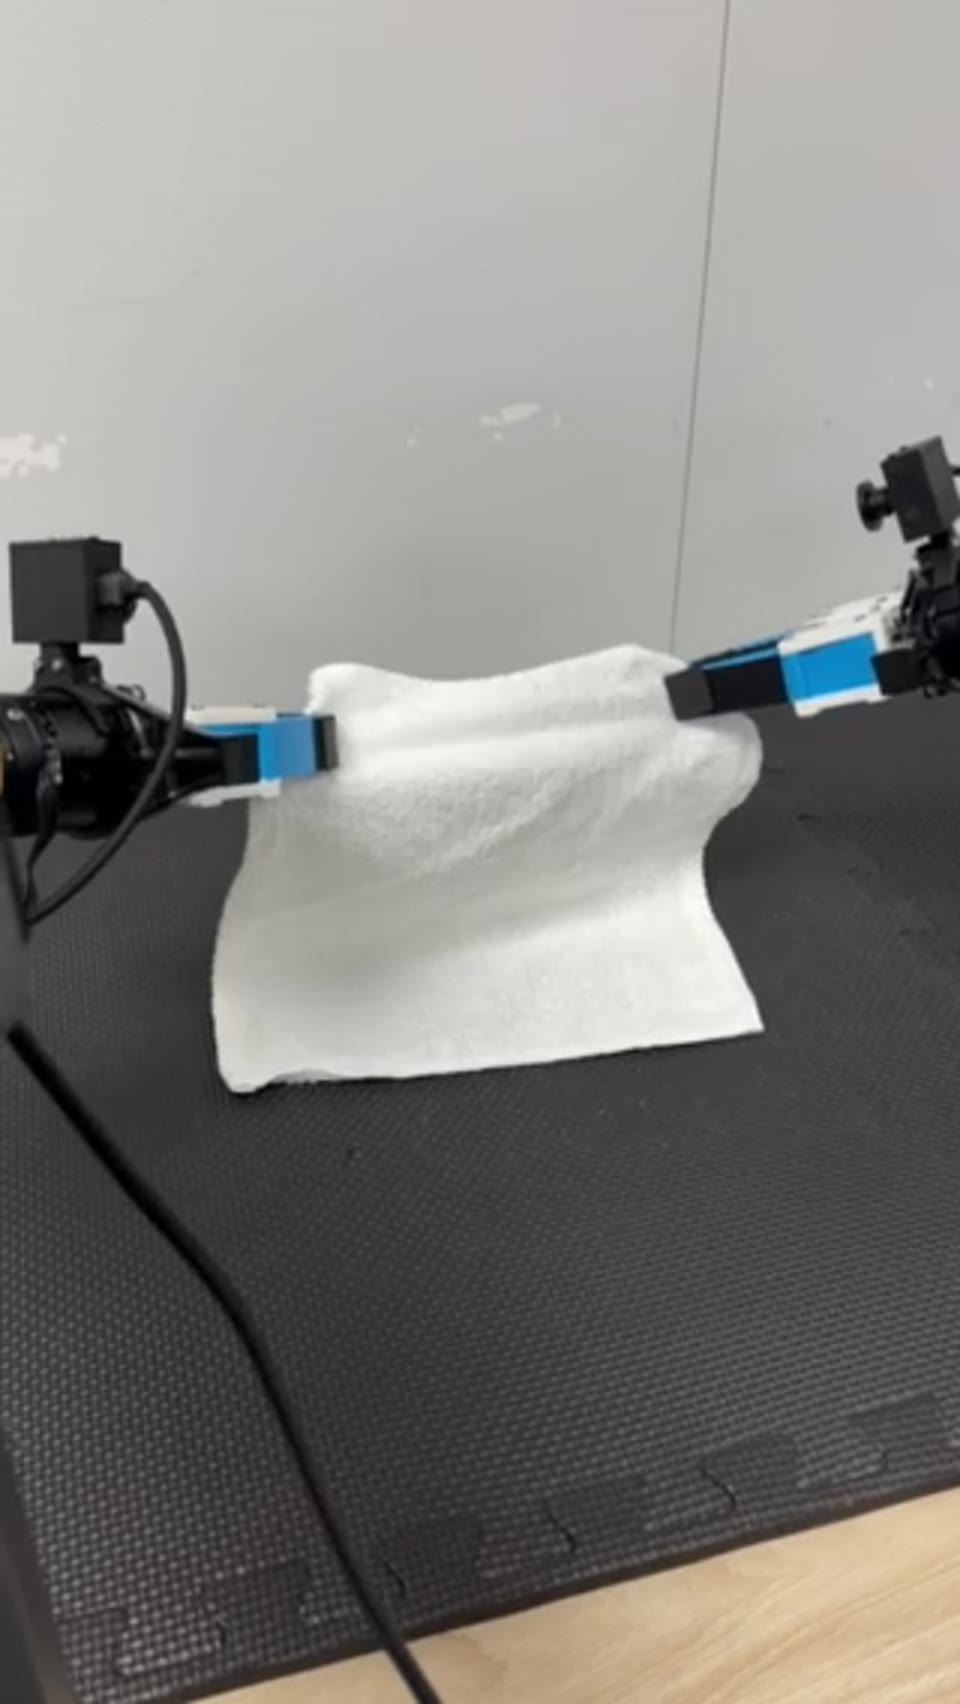
Dual-arm towel manipulation on physical PiPER arms

01 — Recent Work

Dual-arm Robot Learning / π0.5 Deployment

Integrated teleoperation, multi-view data capture, π0.5 inference and physical execution on two AgileX PiPER arms.
Platform
2 × AgileX PiPER
Data
PIKA / UMI · LeRobot-compatible episodes
Tasks
Physical pick-and-place and towel manipulation

Deployment completed; controlled training comparisons remain in progress.

Explore this system ↗

02

Research Trajectory

Education, roles and the systems developed along the way.

Education & Roles

EducationSep 2021 – Jun 2025
BEng Robotics – First-Class HonoursBSc Computer Science
Ocean University of China & Heriot-Watt UniversityJoint programme · Dual degree
EducationSep 2025 – Sep 2026
MRes Medical Robotics and Image-Guided Intervention
Imperial College London
RoleAug 2026 – Present
Embodied AI / Robot Learning InternLatencore AI

Drag to explore · horizontal scroll · focus this region and use ← / →

03 — Explore Projects

Four systems. Different research questions.

Open a card for the problem, contribution and results.

Dual-arm towel manipulation on physical PiPER arms

Dual-arm Robot Learning / π0.5 Deployment

Aug 2026 – Present

Integrated teleoperation, multi-view data capture, π0.5 inference and physical execution on two AgileX PiPER arms.

  • Robot Learning
  • π0.5
  • Teleoperation
Problem, contribution & results
Problem
A successful checkpoint is only one component of a real dual-arm system. Demonstrations, calibration, camera streams, inference timing, trajectory handoff and hardware behaviour must form a reliable loop.
My contribution
Data-workflow integration, π0.5 deployment and physical-system diagnosis.
Results
Physical pick-and-place and towel demos
Explore project ↗
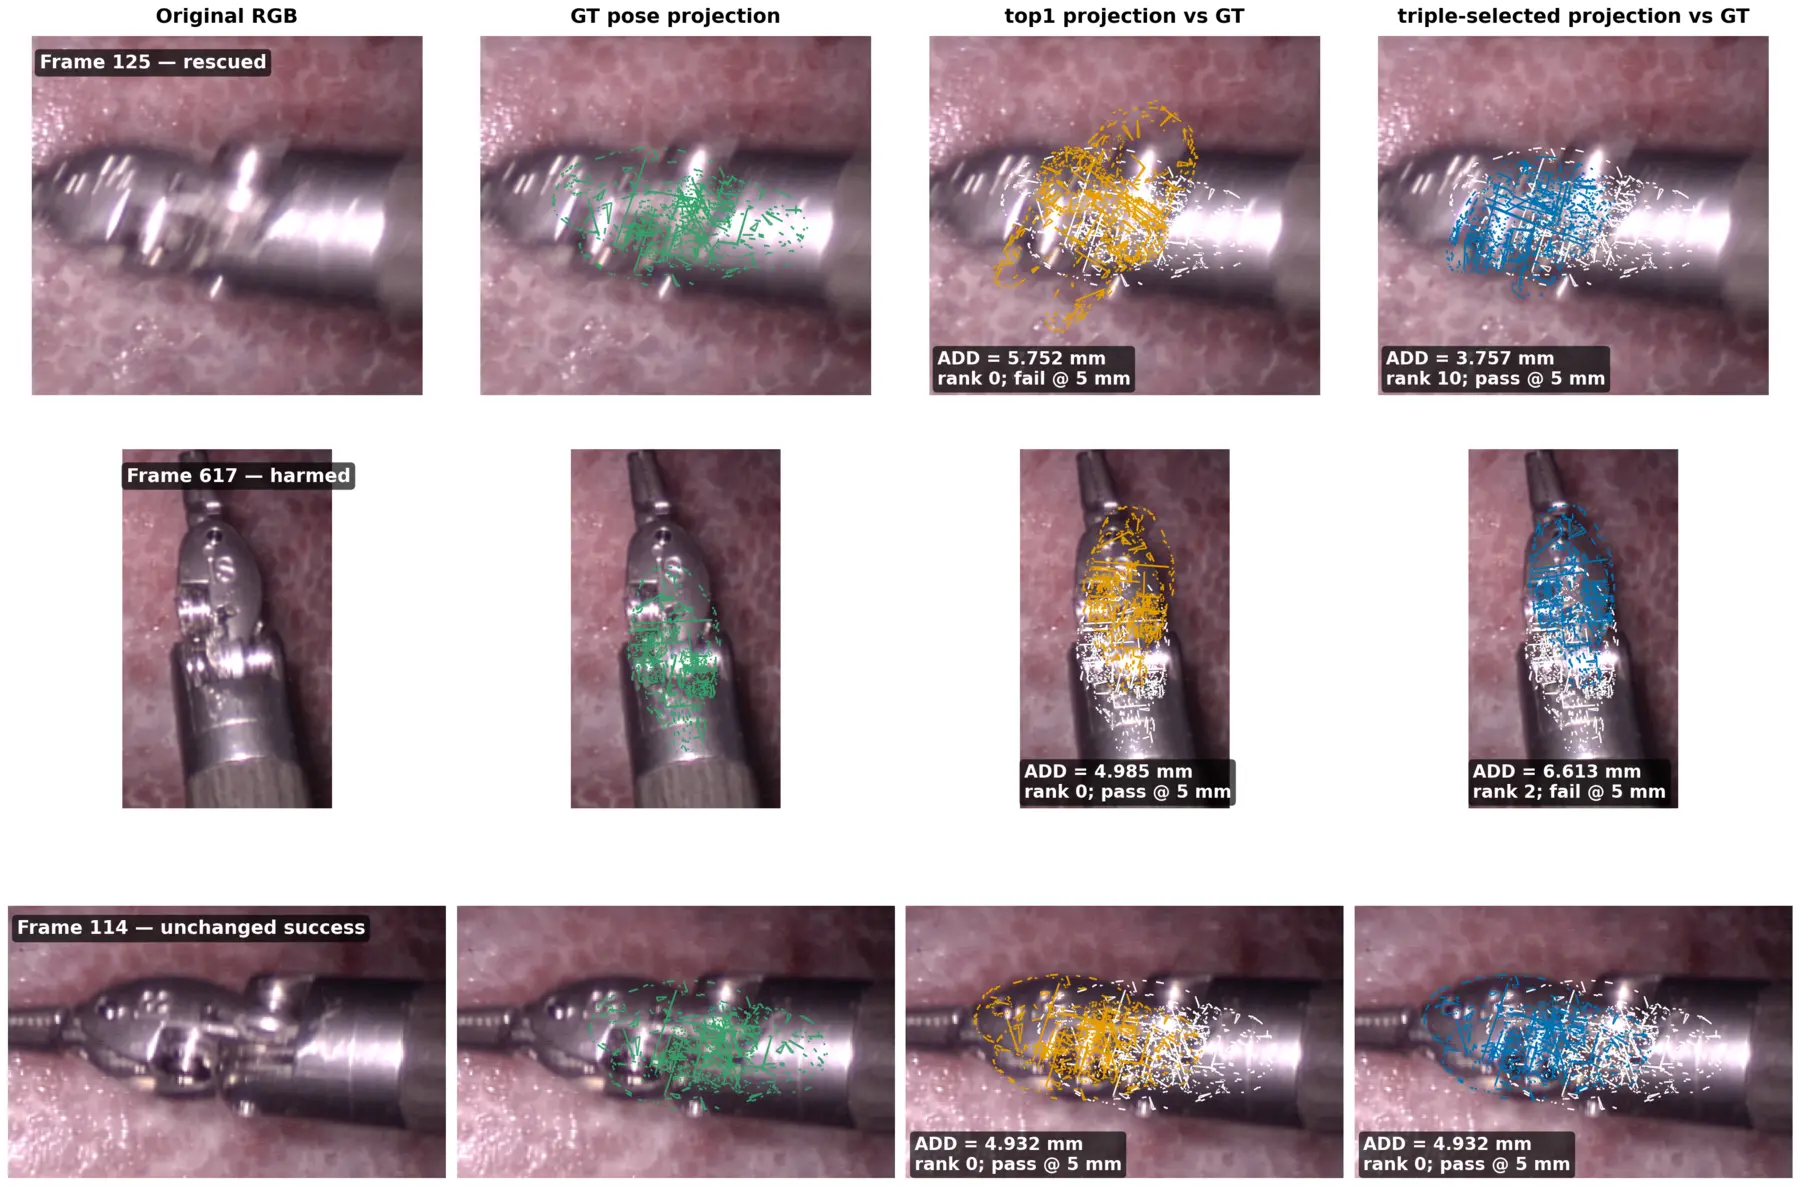
Projected pose candidates and geometric reranking evidence

Zero-Shot 6-DoF Tool Pose Estimation

Large Needle Driver · RGB–Stereo–CAD Pipeline

Mar 2026 – Sep 2026

Symmetry-aware geometric reranking raised top-1 ADD@5 mm from 44.11% to 57.75% across 968 valid pose outputs.

  • 6-DoF Pose
  • Stereo Depth
  • CAD
Problem, contribution & results
Problem
A foundation pose estimator can generate a valid candidate while ranking a geometrically inconsistent pose first. The object is symmetric, thin, partially occluded and evaluated at a strict 5 mm ADD threshold.
My contribution
Individual MRes research on geometric pose reranking and evaluation.
Results
Segmentation, depth and reranking figures
Explore project ↗

Clinical Multi-agent Text-to-SQL

Oct 2025 – Dec 2025

Answered 17 of 20 questions correctly in the team’s project evaluation.
  • Multi-agent
  • LangGraph
  • Text-to-SQL
Problem, contribution & results
Problem
Translate clinical questions into schema-grounded SQL over MIMIC-IV, with validation, repair and safe abstention.
My contribution
Planner-agent design, LangGraph integration and failure-case evaluation.
Results
17 / 20 team evaluation questions
Explore project ↗
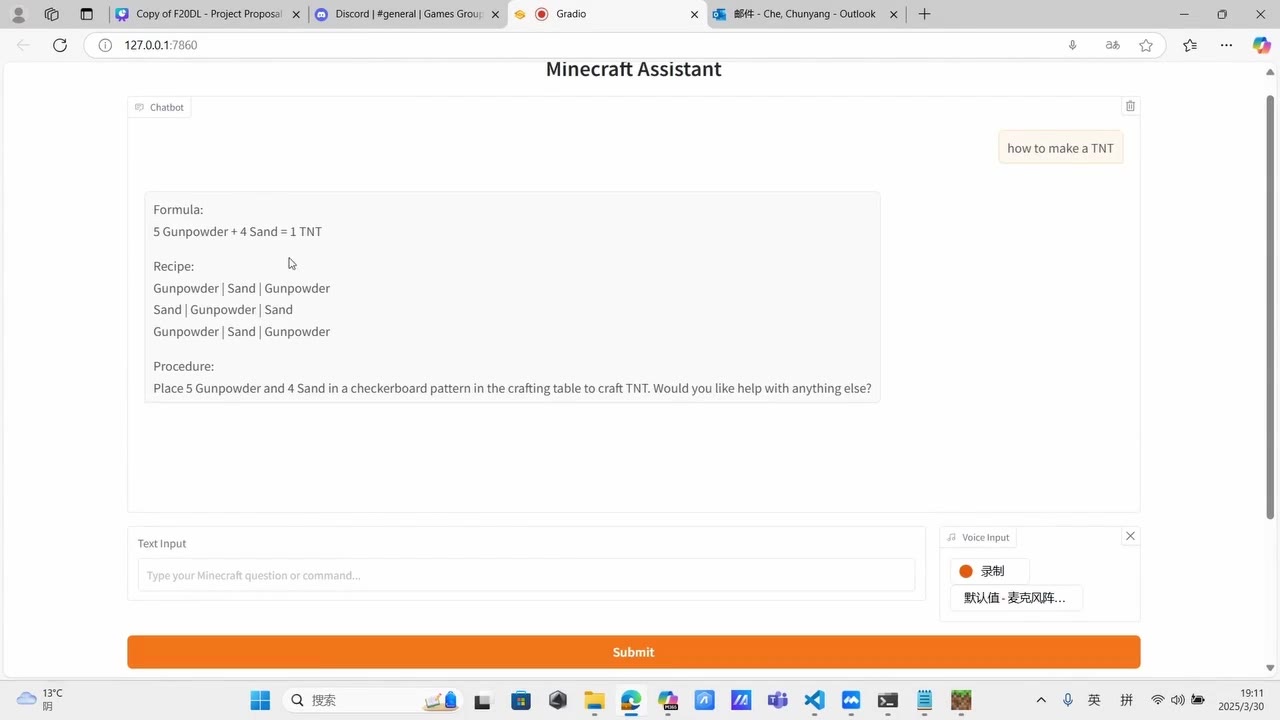
Minecraft team demo

Minecraft Voice Assistant Grounded in Live Game State

Jan 2025 – May 2025

Connected speech, structured live game state and an LLM/API response to parallel voice and interface output.

  • Live State
  • Voice
  • Structured Validation
Problem, contribution & results
Problem
Ground a voice assistant’s responses in structured, live Minecraft game state.
My contribution
Live-state integration, structured validation and responsiveness testing.
Results
Captioned in-game interaction demo
Explore project ↗

04 — Capabilities Across Projects

What I do across projects

All four projects remain accessible. View project cards ↑

05 — About

Research through systems that have to work.

I am interested in where model behaviour meets engineering constraints: how observations are collected, how actions reach hardware, and how failures guide the next experiment.